College application research evidence · understanding and original contribution · Seoul and online
Project courseThe student keeps the work and the record they made.
Georgia Tech: Robot Sensors and Position Finding
Grades 9-12: how robots locate themselves, uncertain...
- Free consultation and level check
- Apgujeong classroom or online
- One-to-one or small group
- Registered academy no. 11882

Is Georgia Tech: Robot Sensors and Position Finding a good fit for high school students in Grades 9-12?
Georgia Tech: Robot Sensors and Position Finding is a good fit for students in grades 9-12 who are interested in how robots locate themselves and uncertain sensor readings. CIT offers online or in-person lessons in Apgujeong, Gangnam, Seoul, in one-to-one or small-group formats. Students make a robot position-finding tool, sensor-error comparison tables and graphs, and recalculation code with test records.
The course starts from open research published by Georgia Tech. Students open a Binder web notebook, express positions on a screen as numbers, and calculate which way a robot is moving. After learning how reference points and sensor information let a robot judge its own position, they change only the sensor error and compare how far the position estimate shifts. The course ends with a position-finding tool: a feature that recalculates position as sensors are added, removed, or given error, and a map screen showing the estimated position and its range of uncertainty. The student then designs and tests an extension of their own: a new question, feature, model, interface, or solution. In an application or interview, the student separates the source research from their own decisions, results, failed attempts, revisions, and limits.
Google sign-in is required. Existing account permissions determine access.
My child found the AI classes interesting and stayed with them. It made for a worthwhile school break. Thank you for teaching so attentively.
- Age group
- Grades 9-12
- Academic subject
- AI & Data, Engineering & Robotics, Physics & SpaceBrowse subject
- Course type
- Course
- Format
- Online or Apgujeong in person · one-to-one or small group
- Teaching language
- Korean by default, with complete English materials
- Curriculum status
- Lesson-readyEvery learning item includes the evidence, worked example, practical work, and tutor guidance required by CIT's lesson-ready standard.
From open research to student-owned work
Students inspect a relevant public source, reproduce the idea, then add an original question, feature, or test. Every source is public, and each lesson names the exact page it opens.
How can I explain this course to my child?
If questions about how robots locate themselves or uncertain sensor readings keep making you ask why, Georgia Tech: Robot Sensors and Position Finding lets you investigate the question with evidence, then build and defend an extension of your own.
Which interests suggest this course?
- how robots locate themselves
- uncertain sensor readings
- positions expressed as numbers
What does the student finish?A robot position-finding tool, sensor-error comparison tables and graphs, and recalculation code with test records.
Is this a good fit?
A strong fit for students who want to understand, build, test, or responsibly use AI systems.
Course placement follows current subject and coding readiness.
Students should be ready to document sources, methods, and limits.
Advanced tools are introduced after a clear baseline.
What will my child learn?
- Calculate position and direction of travel as numbers to describe a robot's motion.
- Judge where the robot is by comparing possibilities as numbers.
- Build a feature that recalculates the position estimate when sensors are added, removed, or given error.
- Explain results on a screen that pairs an error slider with the range of uncertainty on a map.
How does the course progress?
- 1Understanding the Research Question and Baseline Behavior
Open the web notebook, check the data terms, and learn to express positions on a screen as numbers.
- 2Connecting Sensors, Actions, and Measurements
Calculate the robot's direction of travel and trace how reference points and sensors give its position.
- 3Building a Feature and Control Screen from Evidence
Vary only sensor error, collect the results, and code a feature that recalculates position for any sensor mix.
- 4Testing the Integrated App and Explaining the Design
Connect the error slider and the uncertainty map to the feature to complete the position-finding tool.
What counts as useful evidence?
A robot position-finding tool, sensor-error comparison tables and graphs, and recalculation code with test records.
What should an admissions reader be able to see?
The course starts from open research published by Georgia Tech. The student works out what those researchers were trying to learn, why the question matters, and how they tested it, then designs and tests an extension of their own: a new question, feature, model, interface, or solution. In an application or interview, the student separates the source research from their own decisions, results, failed attempts, revisions, and limits.
Useful evidence may include a documented dataset, baseline comparison, model evaluation, error analysis, and a clear record of the student's own decisions.
These names identify who published the open project the course starts from. The evidence an application reads is what the student understood, completed, and can explain.
The real research project this course reads
- gtbook/robotics
- pinned commit
49315552e7f6 - commit date 2026-01-10
- licence BSD-3-Clause for repository code; book prose has separate terms
- text files 94
The student raises the sensor error and watches how far the robot loses track of itself. In class the project is separated into five boxes (input, memory, process, output, control). The lesson opens one of them, changes one value, and leaves the rest closed.
- InputWhat comes in?
The sensor reading each notebook takes in, and the action the robot just made
- Memoryopened hereWhat persists?
The probability spread across every place the robot could be
- ProcessWhat transforms?
The computation that redistributes those probabilities when a new reading arrives
- OutputWhat leaves, and who uses it?
The corrected probabilities, and the next action chosen from them
- ControlWhat decides when anything runs?
The order that alternates acting and observing
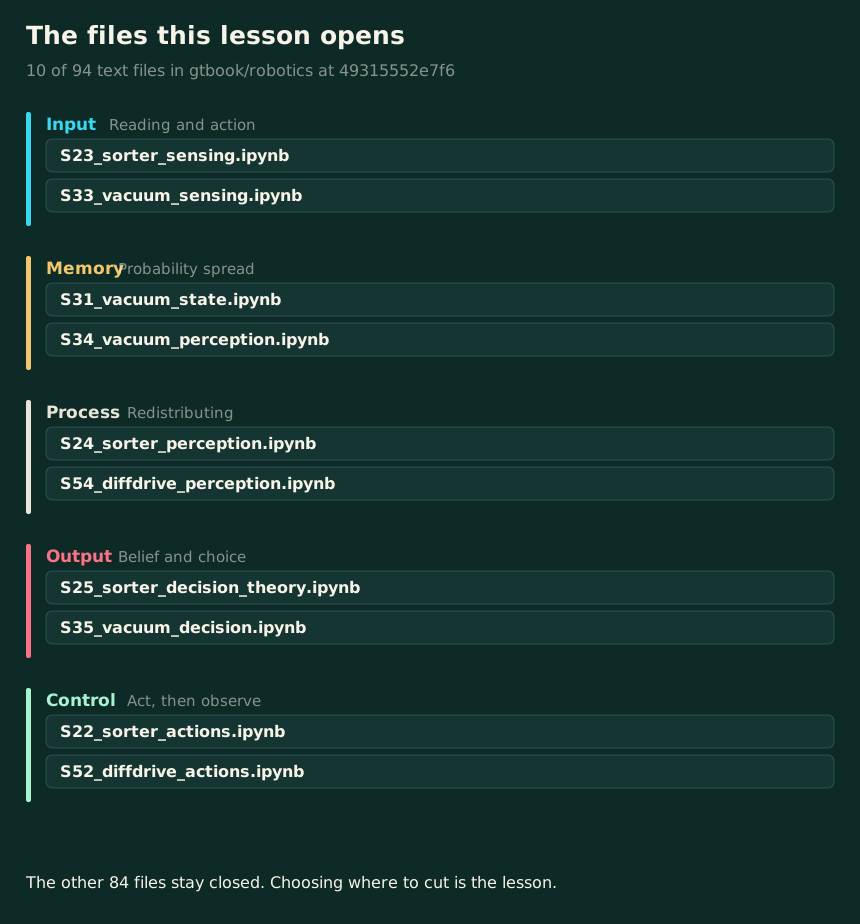
InputReading and action
- S23_sorter_sensing.ipynb
- S33_vacuum_sensing.ipynb
MemoryProbability spread
- S31_vacuum_state.ipynb
- S34_vacuum_perception.ipynb
ProcessRedistributing
- S24_sorter_perception.ipynb
- S54_diffdrive_perception.ipynb
OutputBelief and choice
- S25_sorter_decision_theory.ipynb
- S35_vacuum_decision.ipynb
ControlAct, then observe
- S22_sorter_actions.ipynb
- S52_diffdrive_actions.ipynb
The files the lesson opens, by name. The course is not a walk through the repository; it opens a chosen few and says which.
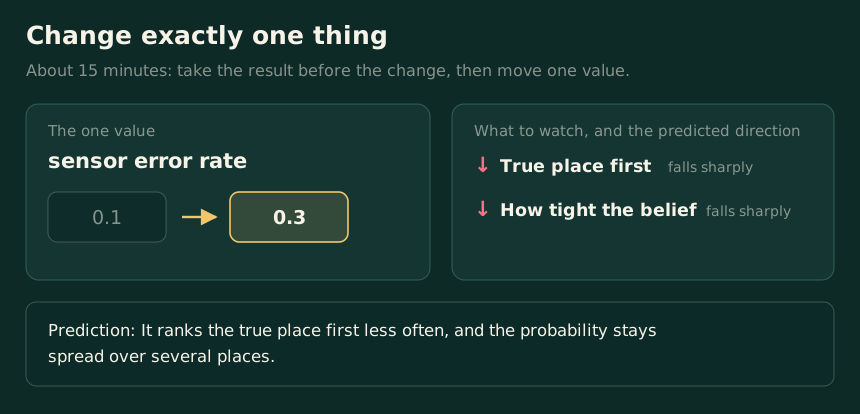
One value moves and everything else stays. The right-hand column is the prediction written before the run, not a result; the work is reconciling the two.
On a narrow screen, swipe the picture sideways.
The universities and labs named here made the open projects this course reads. CIT designed the course independently; it is not an official, affiliated, or endorsed course.
Questions parents search before choosing this course
Is Georgia Tech: Robot Sensors and Position Finding a good fit for high school students in Grades 9-12?
Georgia Tech: Robot Sensors and Position Finding is a good fit for students in grades 9-12 who are interested in how robots locate themselves and uncertain sensor readings. CIT offers online or in-person lessons in Apgujeong, Gangnam, Seoul, in one-to-one or small-group formats. Students make a robot position-finding tool, sensor-error comparison tables and graphs, and recalculation code with test records.
Can my child take Georgia Tech: Robot Sensors and Position Finding online or in person, one-to-one or in a small group?
Yes. CIT offers online and in-person lessons at its Apgujeong academy in Gangnam, Seoul, with one-to-one and small-group options. A readiness consultation confirms the available format and starting point for the course.
Does my child need prior subject knowledge or coding experience for Georgia Tech: Robot Sensors and Position Finding?
Course placement follows current subject and coding readiness. Students should be ready to document sources, methods, and limits. Advanced tools are introduced after a clear baseline.
What will my child make or practice in Georgia Tech: Robot Sensors and Position Finding?
The main evidence is a robot position-finding tool, sensor-error comparison tables and graphs, and recalculation code with test records. Students also document decisions, tests, feedback, and limits in age-appropriate language.
How can Georgia Tech: Robot Sensors and Position Finding show research understanding in a college application?
The course starts from open research published by Georgia Tech. The student works out what those researchers were trying to learn, why the question matters, and how they tested it, then designs and tests an extension of their own: a new question, feature, model, interface, or solution. In an application or interview, the student separates the source research from their own decisions, results, failed attempts, revisions, and limits. Useful evidence may include a documented dataset, baseline comparison, model evaluation, error analysis, and a clear record of the student's own decisions.
How are the schedule and tuition for Georgia Tech: Robot Sensors and Position Finding determined?
CIT confirms the student's readiness, goal, location, class size, and current availability before recommending a course plan. The consultation and level check are free; tuition is explained before enrollment.
When should a student start?
There is no fixed intake month. CIT reviews the student's current school term, readiness, and available hours, then names the point in the course where they should begin.
I appreciated that a simple early idea was extended into an 'AI debate tool'. My child has always been interested in debate and social issues, so seeing that interest connect to the project makes me expect a more complete and distinctive result.
Where else parents check CIT
Choose the course after a readiness check
CIT can compare this course with nearby options by age, subject, and current preparation.