College application research evidence · understanding and original contribution · Seoul and online
Project courseThe student keeps the work and the record they made.
Cornell RCareWorld: Safe Assistive Robots
Grades 9-12: caregiving robots, a robot arm's reach, and...
Where this course comes fromThe universities and labs named here made the open projects or materials this course draws on. CIT designed the course independently; it is not an official, affiliated, or endorsed course of those institutions.
- Cornell UniversityOpen project it is built on
- Free consultation and level check
- Apgujeong classroom or online
- One-to-one or small group
- Registered academy no. 11882

Is Cornell RCareWorld: Safe Assistive Robots a good fit for high school students in Grades 9-12?
Cornell RCareWorld: Safe Assistive Robots is a good fit for students in grades 9-12 who are interested in caregiving robots and a robot arm's reach. CIT offers online or in-person lessons in Apgujeong, Gangnam, Seoul, in one-to-one or small-group formats. Students make a care-robot mission planning app, stop-and-ask-for-help code with unit tests, and LLM safety test records and a 3-minute demo.
The course is built on an open project published by Cornell. In an RCareWorld caregiving scene, students check where people, the robot, and objects are and how far the robot arm can reach, then set an action order that keeps a safe distance. Moving only an object's position shows where the plan fails; from there students build a feature that checks object status and distance and stops to ask for help on failure, plus a care-mission screen. An optional LLM only turns a care request into a draft sequence of allowed action cards, and even that draft moves forward only after human approval and a safety check. The student then designs and tests an extension of their own: a new question, feature, model, interface, or solution. In an application or interview, the student separates the source research from their own decisions, results, failed attempts, revisions, and limits.
Google sign-in is required. Existing account permissions determine access.
My child found the AI classes interesting and stayed with them. It made for a worthwhile school break. Thank you for teaching so attentively.
- Age group
- Grades 9-12
- Academic subject
- AI & Data, Engineering & Robotics, Physics & SpaceBrowse subject
- Course type
- Course
- Format
- Online or Apgujeong in person · one-to-one or small group
- Teaching language
- Korean by default, with complete English materials
- Curriculum status
- Lesson-readyEvery learning item includes the evidence, worked example, practical work, and tutor guidance required by CIT's lesson-ready standard.
From open research to student-owned work
Students inspect a relevant public source, reproduce the idea, then add an original question, feature, or test. The material this course reads was made at Cornell University. Names identify the source, not affiliation or endorsement.
- Cornell UniversityOpen project it is built on
How can I explain this course to my child?
If questions about caregiving robots or a robot arm's reach keep making you ask why, Cornell RCareWorld: Safe Assistive Robots lets you investigate the question with evidence, then build and defend an extension of your own.
Which interests suggest this course?
- caregiving robots
- a robot arm's reach
- safe task order
What does the student finish?A care-robot mission planning app, stop-and-ask-for-help code with unit tests, and LLM safety test records and a 3-minute demo.
Is this a good fit?
A strong fit for students who want to understand, build, test, or responsibly use AI systems.
Course placement follows current subject and coding readiness.
Students should be ready to document sources, methods, and limits.
Advanced tools are introduced after a clear baseline.
What will my child learn?
- Explain with examples how safe distance and a robot arm's reach change the order of a task.
- Turn the failures from an experiment that moves only an object's position into feature requirements.
- Build a feature that runs an action order while checking objects and distance and stops to ask for help on failure.
- Test how far the LLM draft feature will go with normal, ambiguous, and rule-dodging requests.
- Cornell UniversityOpen project it is built on
How does the course progress?
- 1Understanding the Research Question and Baseline Behavior
Confirm the safety range of the virtual care scene and the setup, then map where people, the robot, and objects are.
- 2Connecting Sensors, Actions, and Measurements
Check the robot arm's reach and design a safe action order that keeps distance from people.
- 3Building a Feature and Control Screen from Evidence
Vary only an object's position, compare results, and code a feature that stops and asks for help on failure.
- 4Testing the Integrated App and Explaining the Design
Connect the LLM draft feature to a care-mission screen that shows each state and why help was requested.
What counts as useful evidence?
A care-robot mission planning app, stop-and-ask-for-help code with unit tests, and LLM safety test records and a 3-minute demo.
What should an admissions reader be able to see?
The course is built on an open project published by Cornell. The student works out what those researchers were trying to learn, why the question matters, and how they tested it, then designs and tests an extension of their own: a new question, feature, model, interface, or solution. In an application or interview, the student separates the source research from their own decisions, results, failed attempts, revisions, and limits.
Useful evidence may include a documented dataset, baseline comparison, model evaluation, error analysis, and a clear record of the student's own decisions.
These names identify who published the open project the course starts from. The evidence an application reads is what the student understood, completed, and can explain.
The real research project this course reads
- empriselab/RCareWorld
- pinned commit
ae0900be3e45 - commit date 2025-02-12
- licence Apache-2.0
- text files 438
The student widens one safety distance in a care-robot simulation and sees how the way it works changes. In class the project is separated into five boxes (input, memory, process, output, control). The lesson opens one of them, changes one value, and leaves the rest closed.
- InputWhat comes in?
How the person and the objects are placed, and what the camera and touch sensors send back
- MemoryWhat persists?
The attribute values attached to every object in the scene
- ProcessWhat transforms?
Deciding where the hand should be and solving the joint angles that take it there
- OutputWhat leaves, and who uses it?
The rendered picture, the values the sensors return, and whether the task finished
- Controlopened hereWhat decides when anything runs?
The turn-taking that lets the Python side and the display program advance one step each
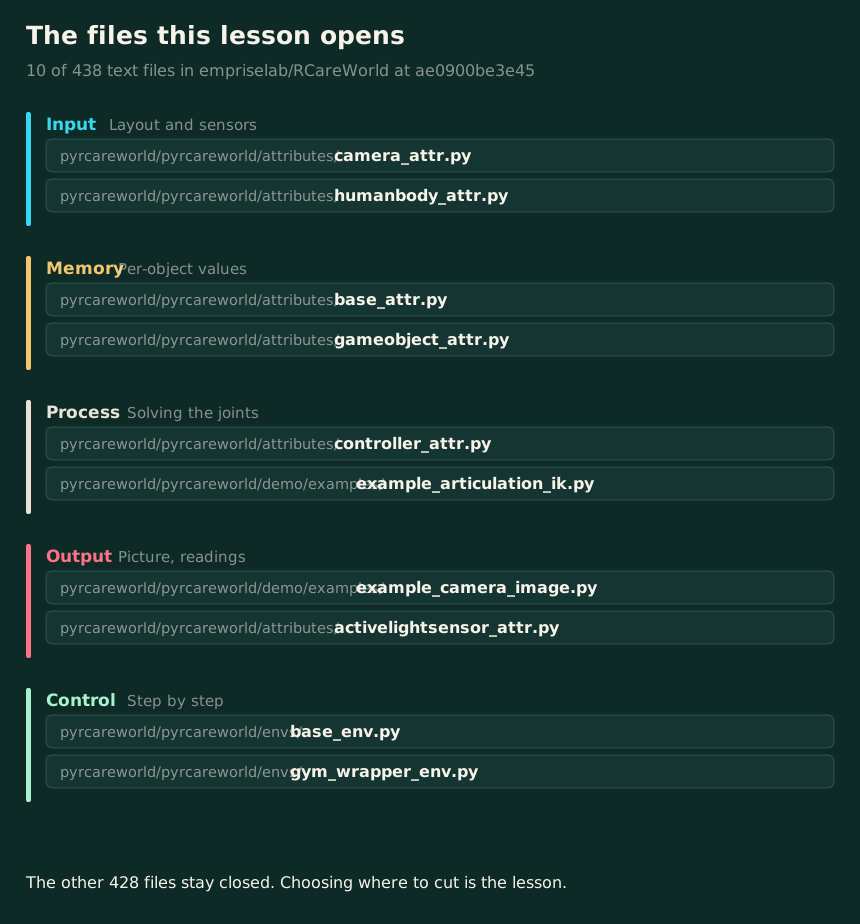
InputLayout and sensors
pyrcareworld/pyrcareworld/attributes/camera_attr.pypyrcareworld/pyrcareworld/attributes/humanbody_attr.py
MemoryPer-object values
pyrcareworld/pyrcareworld/attributes/base_attr.pypyrcareworld/pyrcareworld/attributes/gameobject_attr.py
ProcessSolving the joints
pyrcareworld/pyrcareworld/attributes/controller_attr.pypyrcareworld/pyrcareworld/demo/examples/example_articulation_ik.py
OutputPicture, readings
pyrcareworld/pyrcareworld/demo/examples/example_camera_image.pypyrcareworld/pyrcareworld/attributes/activelightsensor_attr.py
ControlStep by step
pyrcareworld/pyrcareworld/envs/base_env.pypyrcareworld/pyrcareworld/envs/gym_wrapper_env.py
The files the lesson opens, by name. The course is not a walk through the repository; it opens a chosen few and says which.
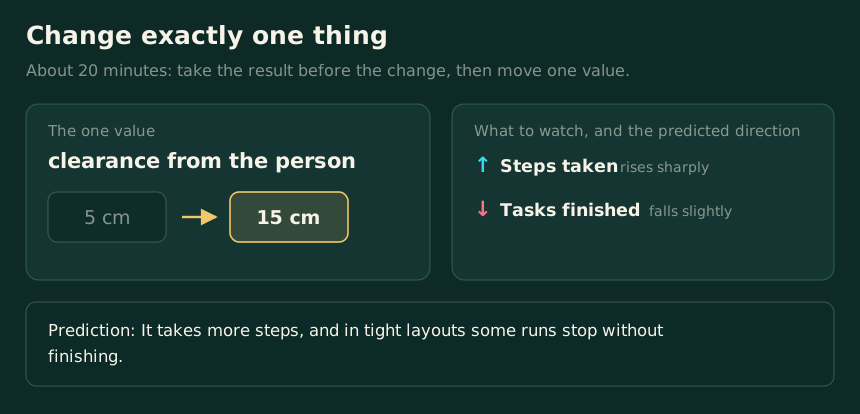
One value moves and everything else stays. The right-hand column is the prediction written before the run, not a result; the work is reconciling the two.
On a narrow screen, swipe the picture sideways.
The universities and labs named here made the open projects this course reads. CIT designed the course independently; it is not an official, affiliated, or endorsed course.
- Cornell UniversityOpen project it is built on
Questions parents search before choosing this course
Is Cornell RCareWorld: Safe Assistive Robots a good fit for high school students in Grades 9-12?
Cornell RCareWorld: Safe Assistive Robots is a good fit for students in grades 9-12 who are interested in caregiving robots and a robot arm's reach. CIT offers online or in-person lessons in Apgujeong, Gangnam, Seoul, in one-to-one or small-group formats. Students make a care-robot mission planning app, stop-and-ask-for-help code with unit tests, and LLM safety test records and a 3-minute demo.
Can my child take Cornell RCareWorld: Safe Assistive Robots online or in person, one-to-one or in a small group?
Yes. CIT offers online and in-person lessons at its Apgujeong academy in Gangnam, Seoul, with one-to-one and small-group options. A readiness consultation confirms the available format and starting point for the course.
Does my child need prior subject knowledge or coding experience for Cornell RCareWorld: Safe Assistive Robots?
Course placement follows current subject and coding readiness. Students should be ready to document sources, methods, and limits. Advanced tools are introduced after a clear baseline.
What will my child make or practice in Cornell RCareWorld: Safe Assistive Robots?
The main evidence is a care-robot mission planning app, stop-and-ask-for-help code with unit tests, and LLM safety test records and a 3-minute demo. Students also document decisions, tests, feedback, and limits in age-appropriate language.
How can Cornell RCareWorld: Safe Assistive Robots show research understanding in a college application?
The course is built on an open project published by Cornell. The student works out what those researchers were trying to learn, why the question matters, and how they tested it, then designs and tests an extension of their own: a new question, feature, model, interface, or solution. In an application or interview, the student separates the source research from their own decisions, results, failed attempts, revisions, and limits. Useful evidence may include a documented dataset, baseline comparison, model evaluation, error analysis, and a clear record of the student's own decisions.
How are the schedule and tuition for Cornell RCareWorld: Safe Assistive Robots determined?
CIT confirms the student's readiness, goal, location, class size, and current availability before recommending a course plan. The consultation and level check are free; tuition is explained before enrollment.
When should a student start?
There is no fixed intake month. CIT reviews the student's current school term, readiness, and available hours, then names the point in the course where they should begin.
I appreciated that a simple early idea was extended into an 'AI debate tool'. My child has always been interested in debate and social issues, so seeing that interest connect to the project makes me expect a more complete and distinctive result.
Where else parents check CIT
Choose the course after a readiness check
CIT can compare this course with nearby options by age, subject, and current preparation.